
Student team @ Politecnico di Torino We design and build underwater ROVs for the international MATE ROV Competition.
Individually we are one drop, together we are an Ocean.
🌐 Website ·
📘 Handbook ·
💼 LinkedIn ·
📷 Instagram ·
PoliTOcean is a student team from Politecnico di Torino, founded in 2017. We design, build and program ROVs (Remotely Operated Vehicles) — remotely operated underwater robots — and compete every year in the MATE ROV Competition in the United States.
The team is organized into three departments:
- 🔧 MATE — mechanics, electronics and firmware of the ROV
- 🔬 R&D — research on hydrodynamics, materials and new technologies
- 📣 Communication & Marketing — communication, graphics and sponsors
Firmware, ROS 2, control software and tools.
| Repo | Description |
|---|---|
nereo_ros2_code |
ROS 2 code for the Nereo ROV |
nereo_FC_firmware |
Flight controller firmware (STM32F460VIT6) |
Oceanix |
ROV control software: sensors, communication, motors |
NEXUS |
Control GUI for EVA |
ros2_controller_tuning_aid |
ROS 2 package for tuning vehicle controllers |
Float |
Firmware for the float project |
website |
The team's official website |
Our PCBs, designed in KiCad. Every board has automatic renders, an interactive BOM you can open in the browser, and production files generated at every change.
| Board | Links | |
|---|---|---|
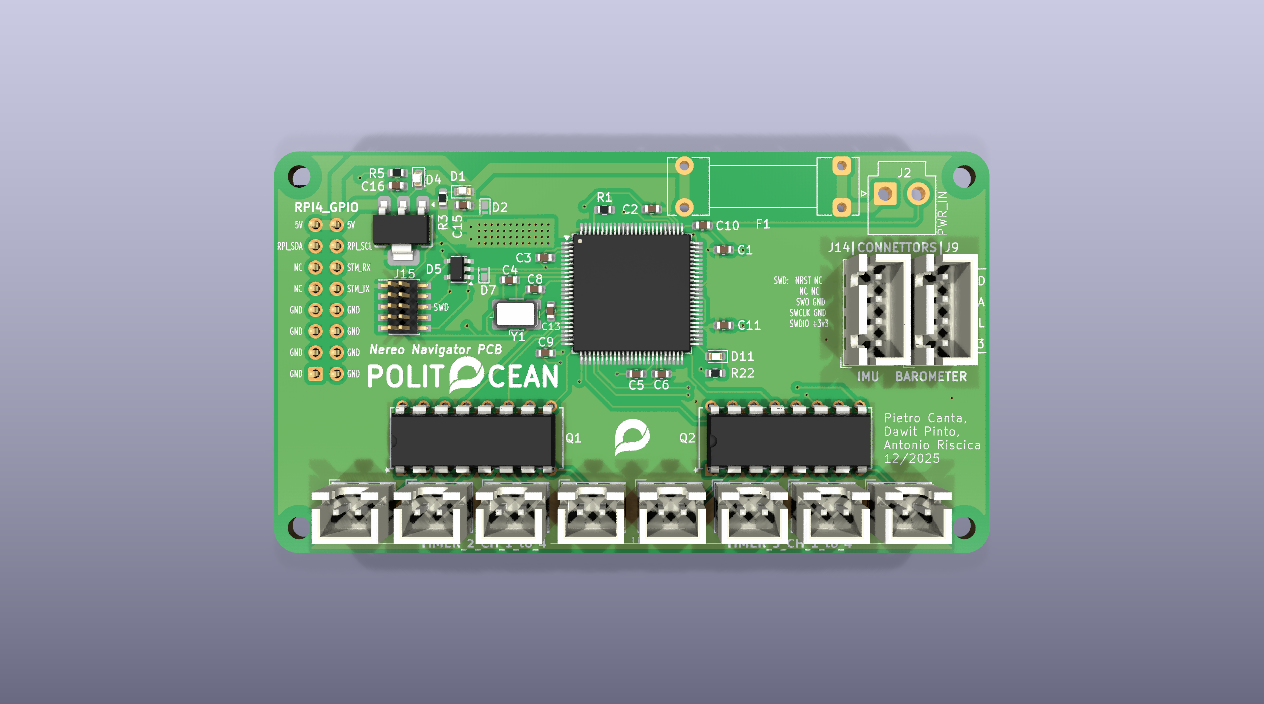 |
Nereo flight controller STM32F4, 2 layers |
Repo · Interactive BOM · Firmware |
- Every repo has a topic:
softwareorelectronics. The topic decides which team can work on it. - Repo names follow
<rov>_<component>_<type>, e.g.nereo_FC_firmwareandnereo_FC_pcb. - Starting a new board? Use
template_electronics: renders, interactive BOM and production files come for free. - Always open a pull request: no direct pushes to
main.
New to the team or want to know how we work? Read our handbook & internal docs → (onboarding, organization, processes).
Are you a Polito student passionate about underwater robotics? Apply here → or reach out at politocean@gmail.com.

